about
I study CS at CMU, with a focus in ML. Generally interested in many things, including generative models and their underlying theory; reinforcement learning; foundation models in language and robotics and their connections.
Connect with me! Always eager to chat and talk about the latest research/news. Share some stuff you're working on, or others' work you find interesting : )
projects
2026
CoinRun World ModelBuilt a training pipeline for a world model of the 2D platformer CoinRun (an RL benchmark). I downsized Oasis's Minecraft world-model architecture: a spatiotemporal DiT conditioned on keyboard actions via AdaLN-style conditioning, and on prior context frames (including the initial prompt frame), which generates video frames with DDIM in pixel space, autoregressively (diffusion forcing). I also ran a scaling analysis over toy model sizes from 5M to 58M parameters on a log-log scale.github
2025
Real2Sim and Real2Sim2Real Cloth Folding1. How does varying simulation data fidelity affect sim2real performance?
2. How can next-generation (differentiable) physics simulation data be leveraged for post-training policies?Built a real2sim pipeline in NVIDIA Newton, with domain randomization (varying cloth meshes, physics engine solvers, and the cloth's stiffness, damping and particle size, etc.) to generate ~10K heuristic-based cloth-folding demonstrations for downstream policies: imitation-learning paradigms like diffusion policy, or post-training foundation models. Also explored a real2sim2real pipeline by developing hardware drivers and infrastructure for creating a digital twin from teleop → sim.
2. How can next-generation (differentiable) physics simulation data be leveraged for post-training policies?Built a real2sim pipeline in NVIDIA Newton, with domain randomization (varying cloth meshes, physics engine solvers, and the cloth's stiffness, damping and particle size, etc.) to generate ~10K heuristic-based cloth-folding demonstrations for downstream policies: imitation-learning paradigms like diffusion policy, or post-training foundation models. Also explored a real2sim2real pipeline by developing hardware drivers and infrastructure for creating a digital twin from teleop → sim.
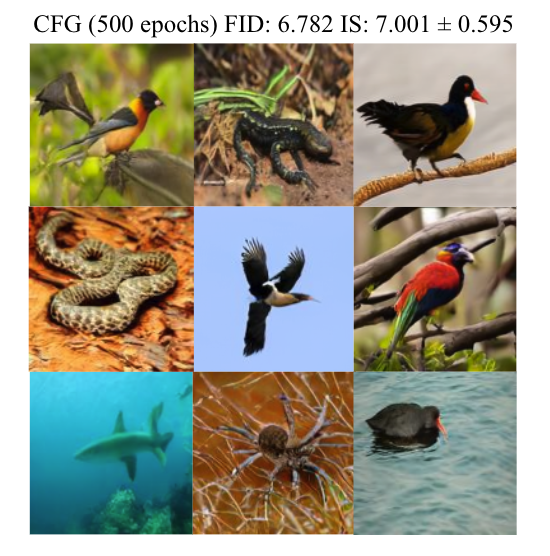
Image GenerationImplemented DDPM/DDIM with CFG and VAE encoding trained with UNet on ImageNet-100 with 8xH100s on PSC. Also tried VAE reconstruction on faces.
Household RobotFinetuned VLA (π0.5, SmolVLA) on cloth folding tasks, succeeding almost 100% of time on trained tasks - pretraining allows robot to adapt to disruptions/mistakes as well.
2024
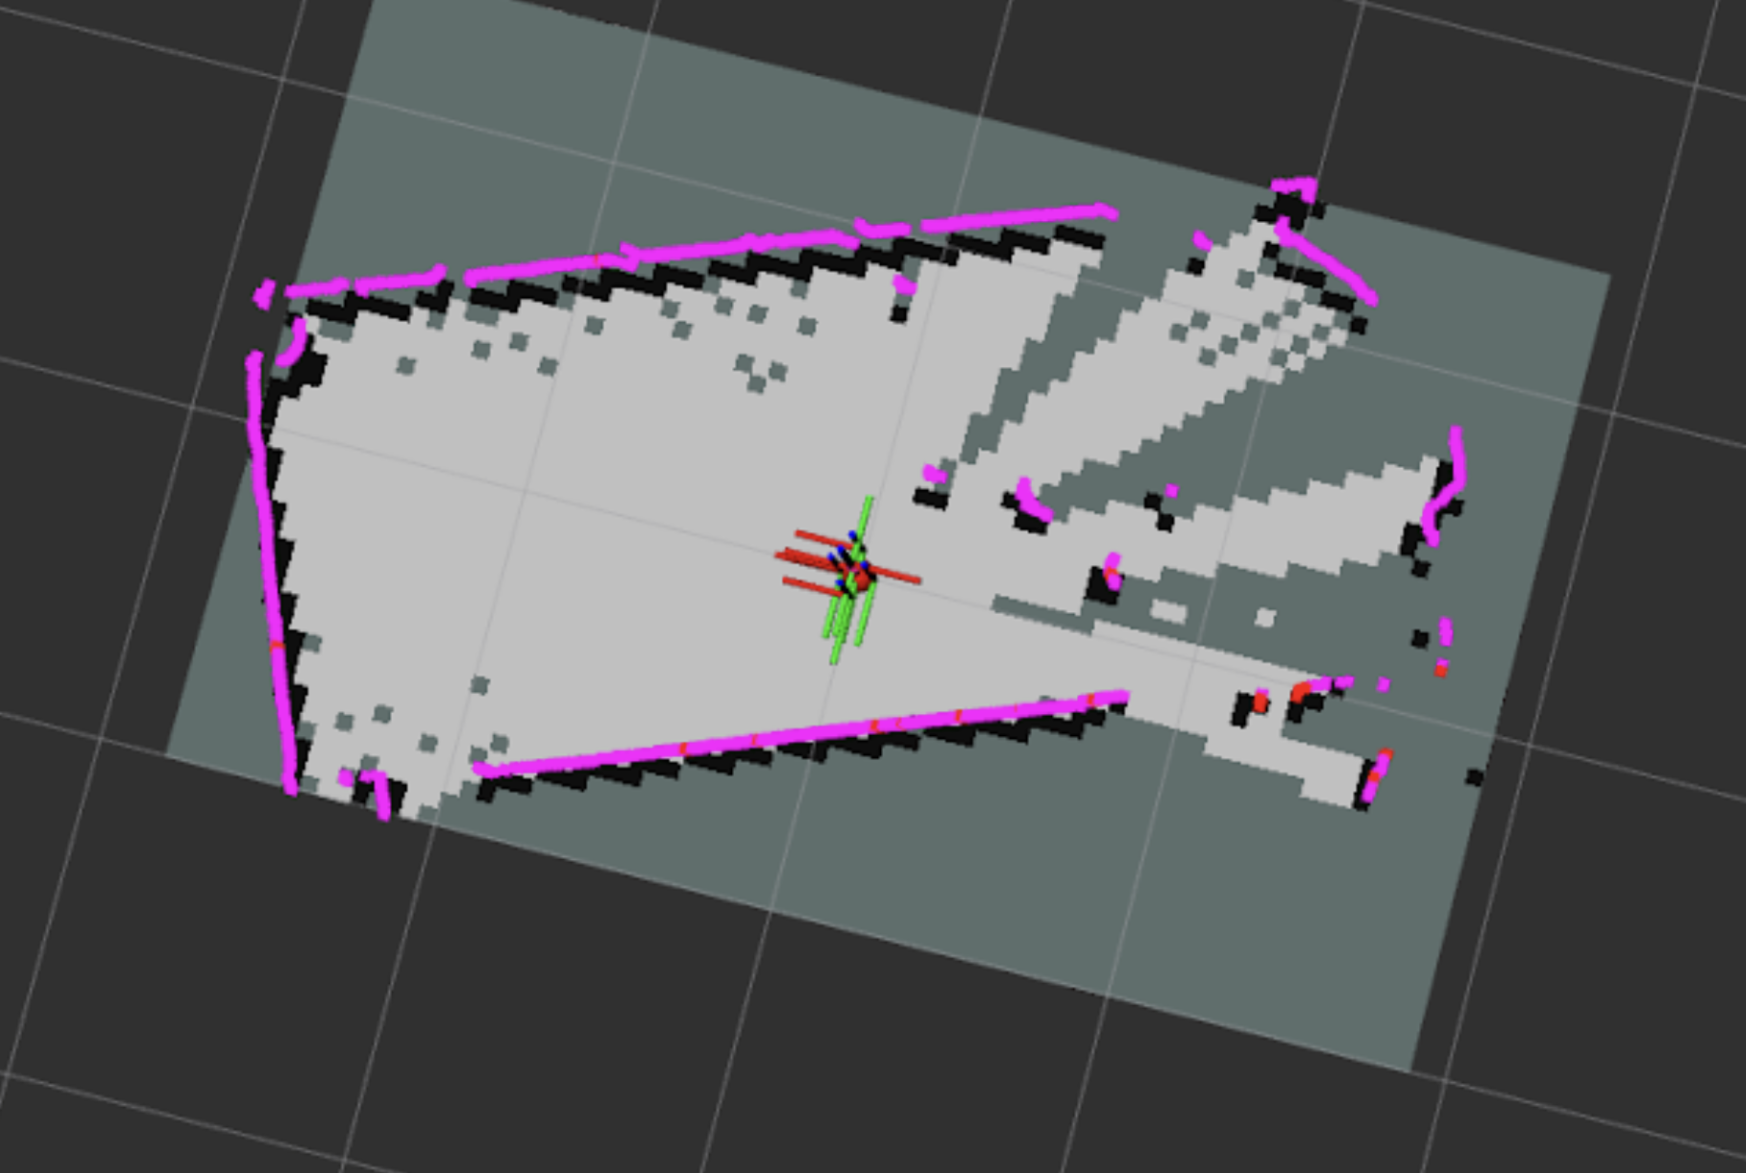
SLAM RobotImplemented differential drive controller, EKF, sensor fusion, and 2D LiDAR SLAM in ROS2 Humble - simulated in Gazebo.
2023
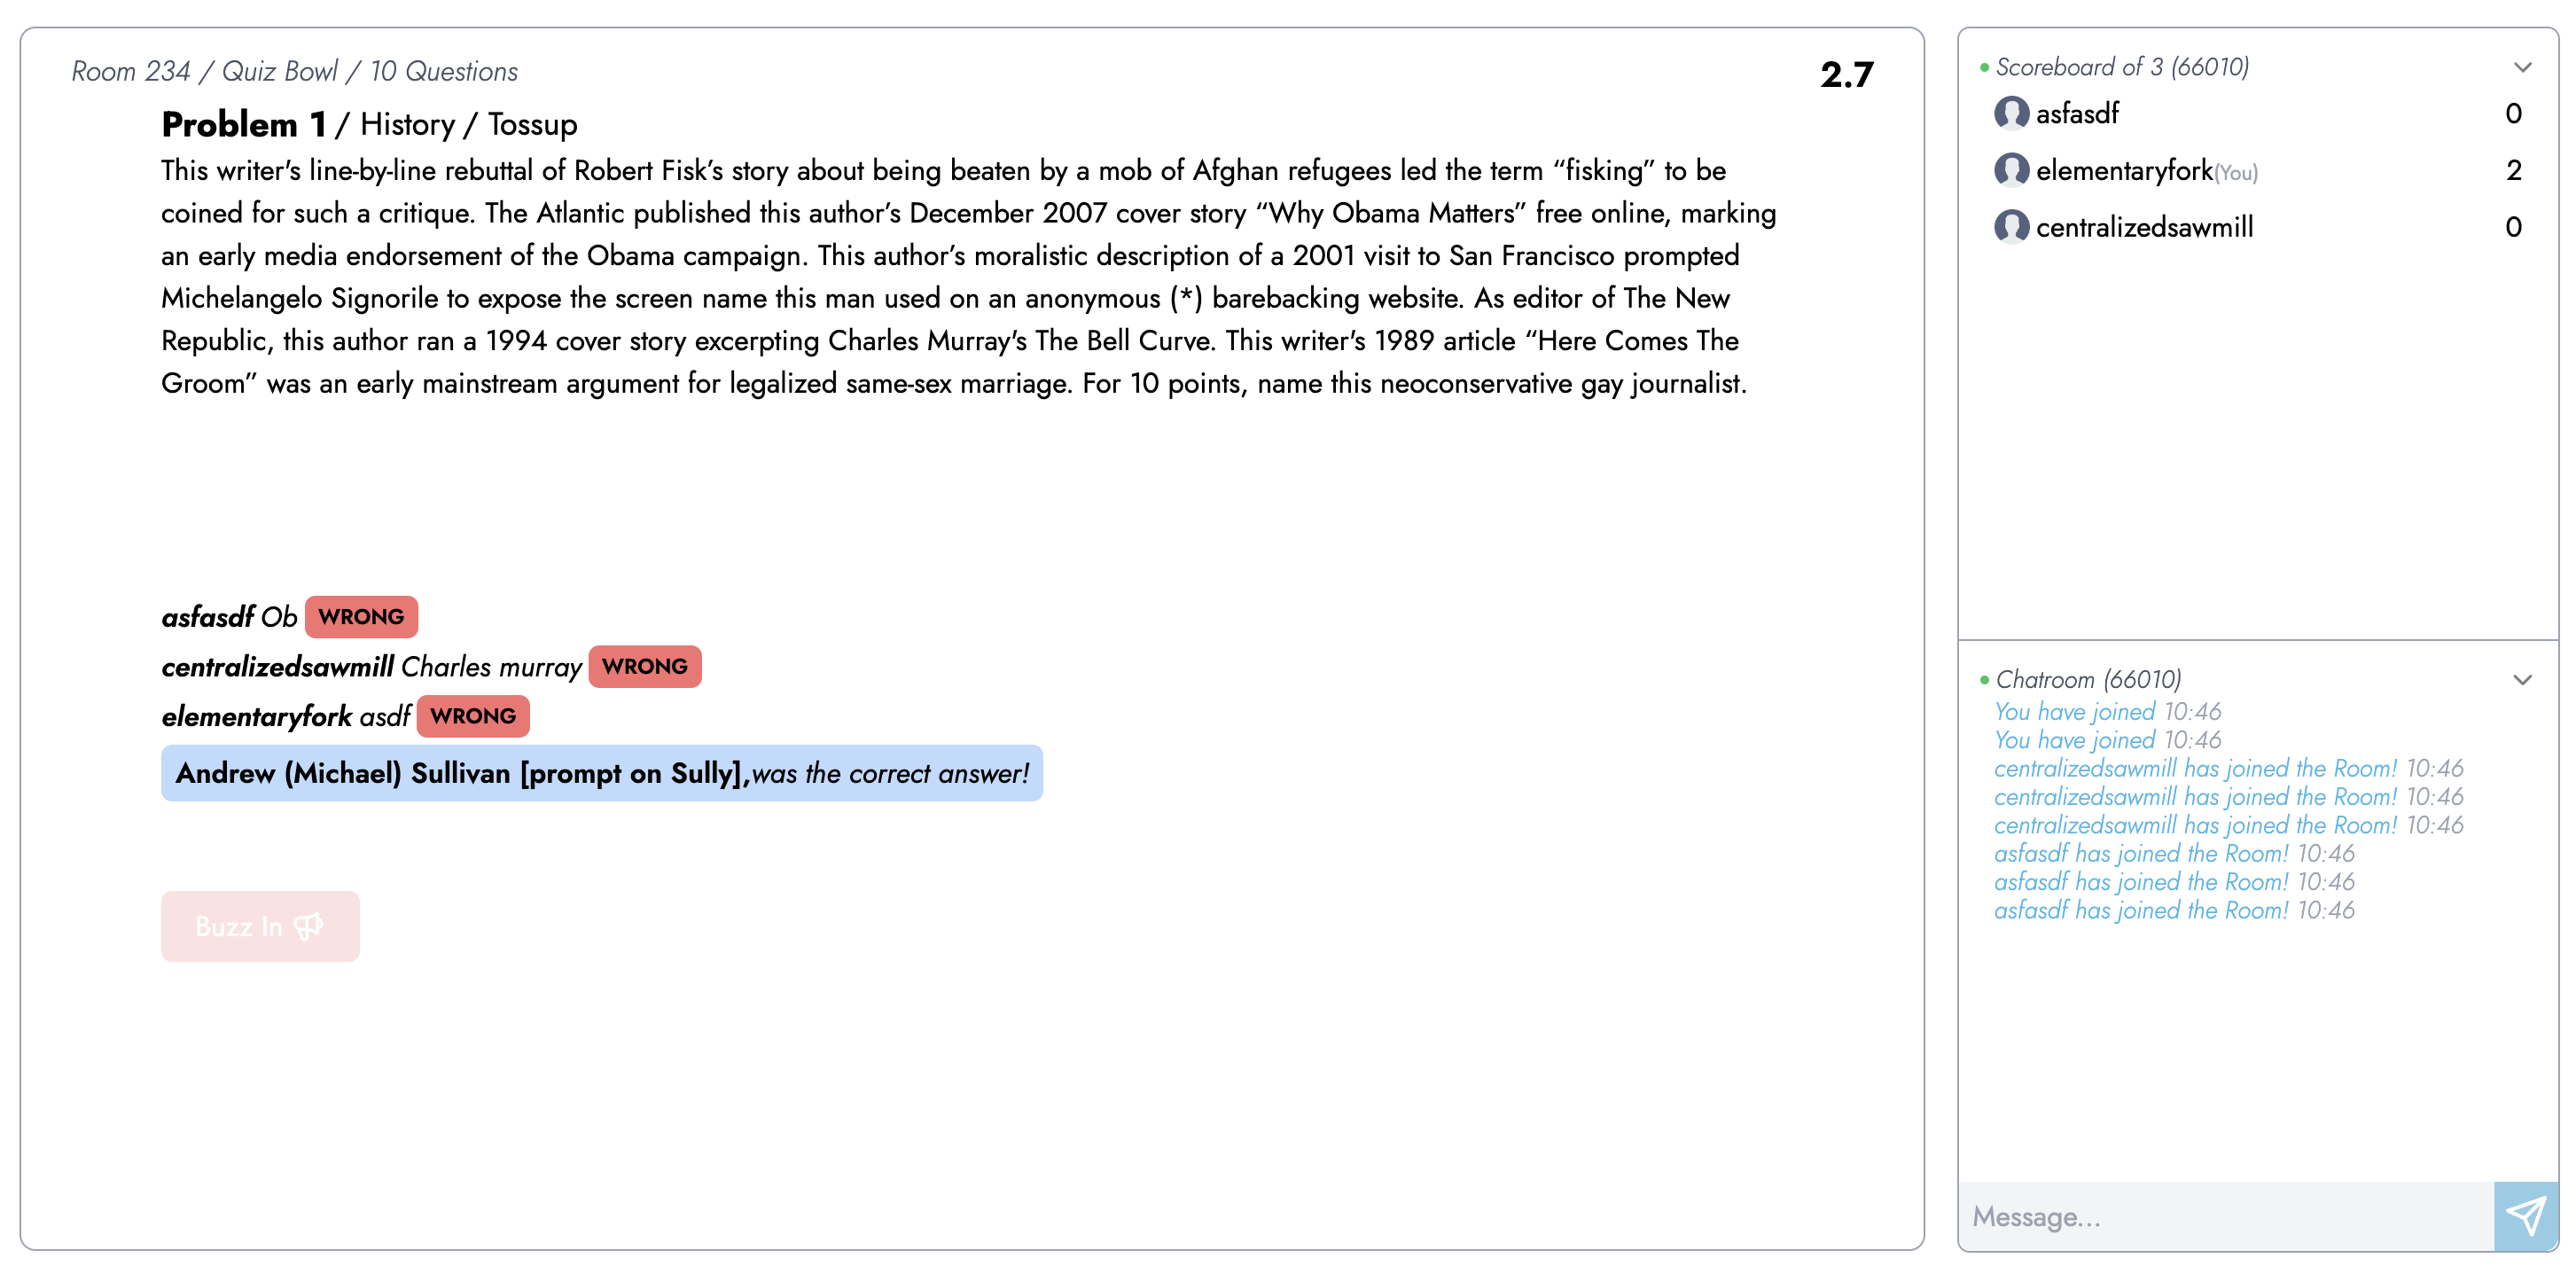
STEM Competition Web AppDesigned and built a multiplayer web app for lobbies and competing against players in science bowl/mathcounts Countdown games in real-time before agentic IDEs existed.
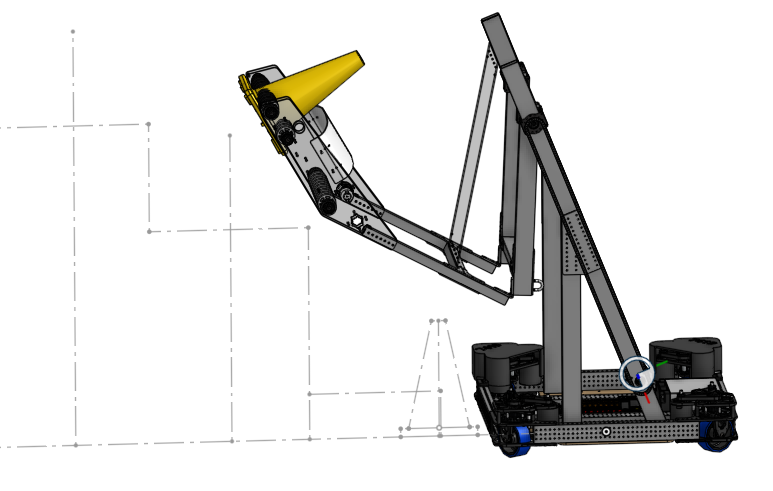
FRC 7419 (9919) ChargedUp RobotLed the design, fabrication, assembly, and programming of a) omnidirectional drivetrain b) lowered center of gravity c) lower four-bar arm linkage for FRC 7419's offseason "ChargedUp" Robot - This year's game aimed to pick-and-place cube balloons and traffic cones in versatile positions.
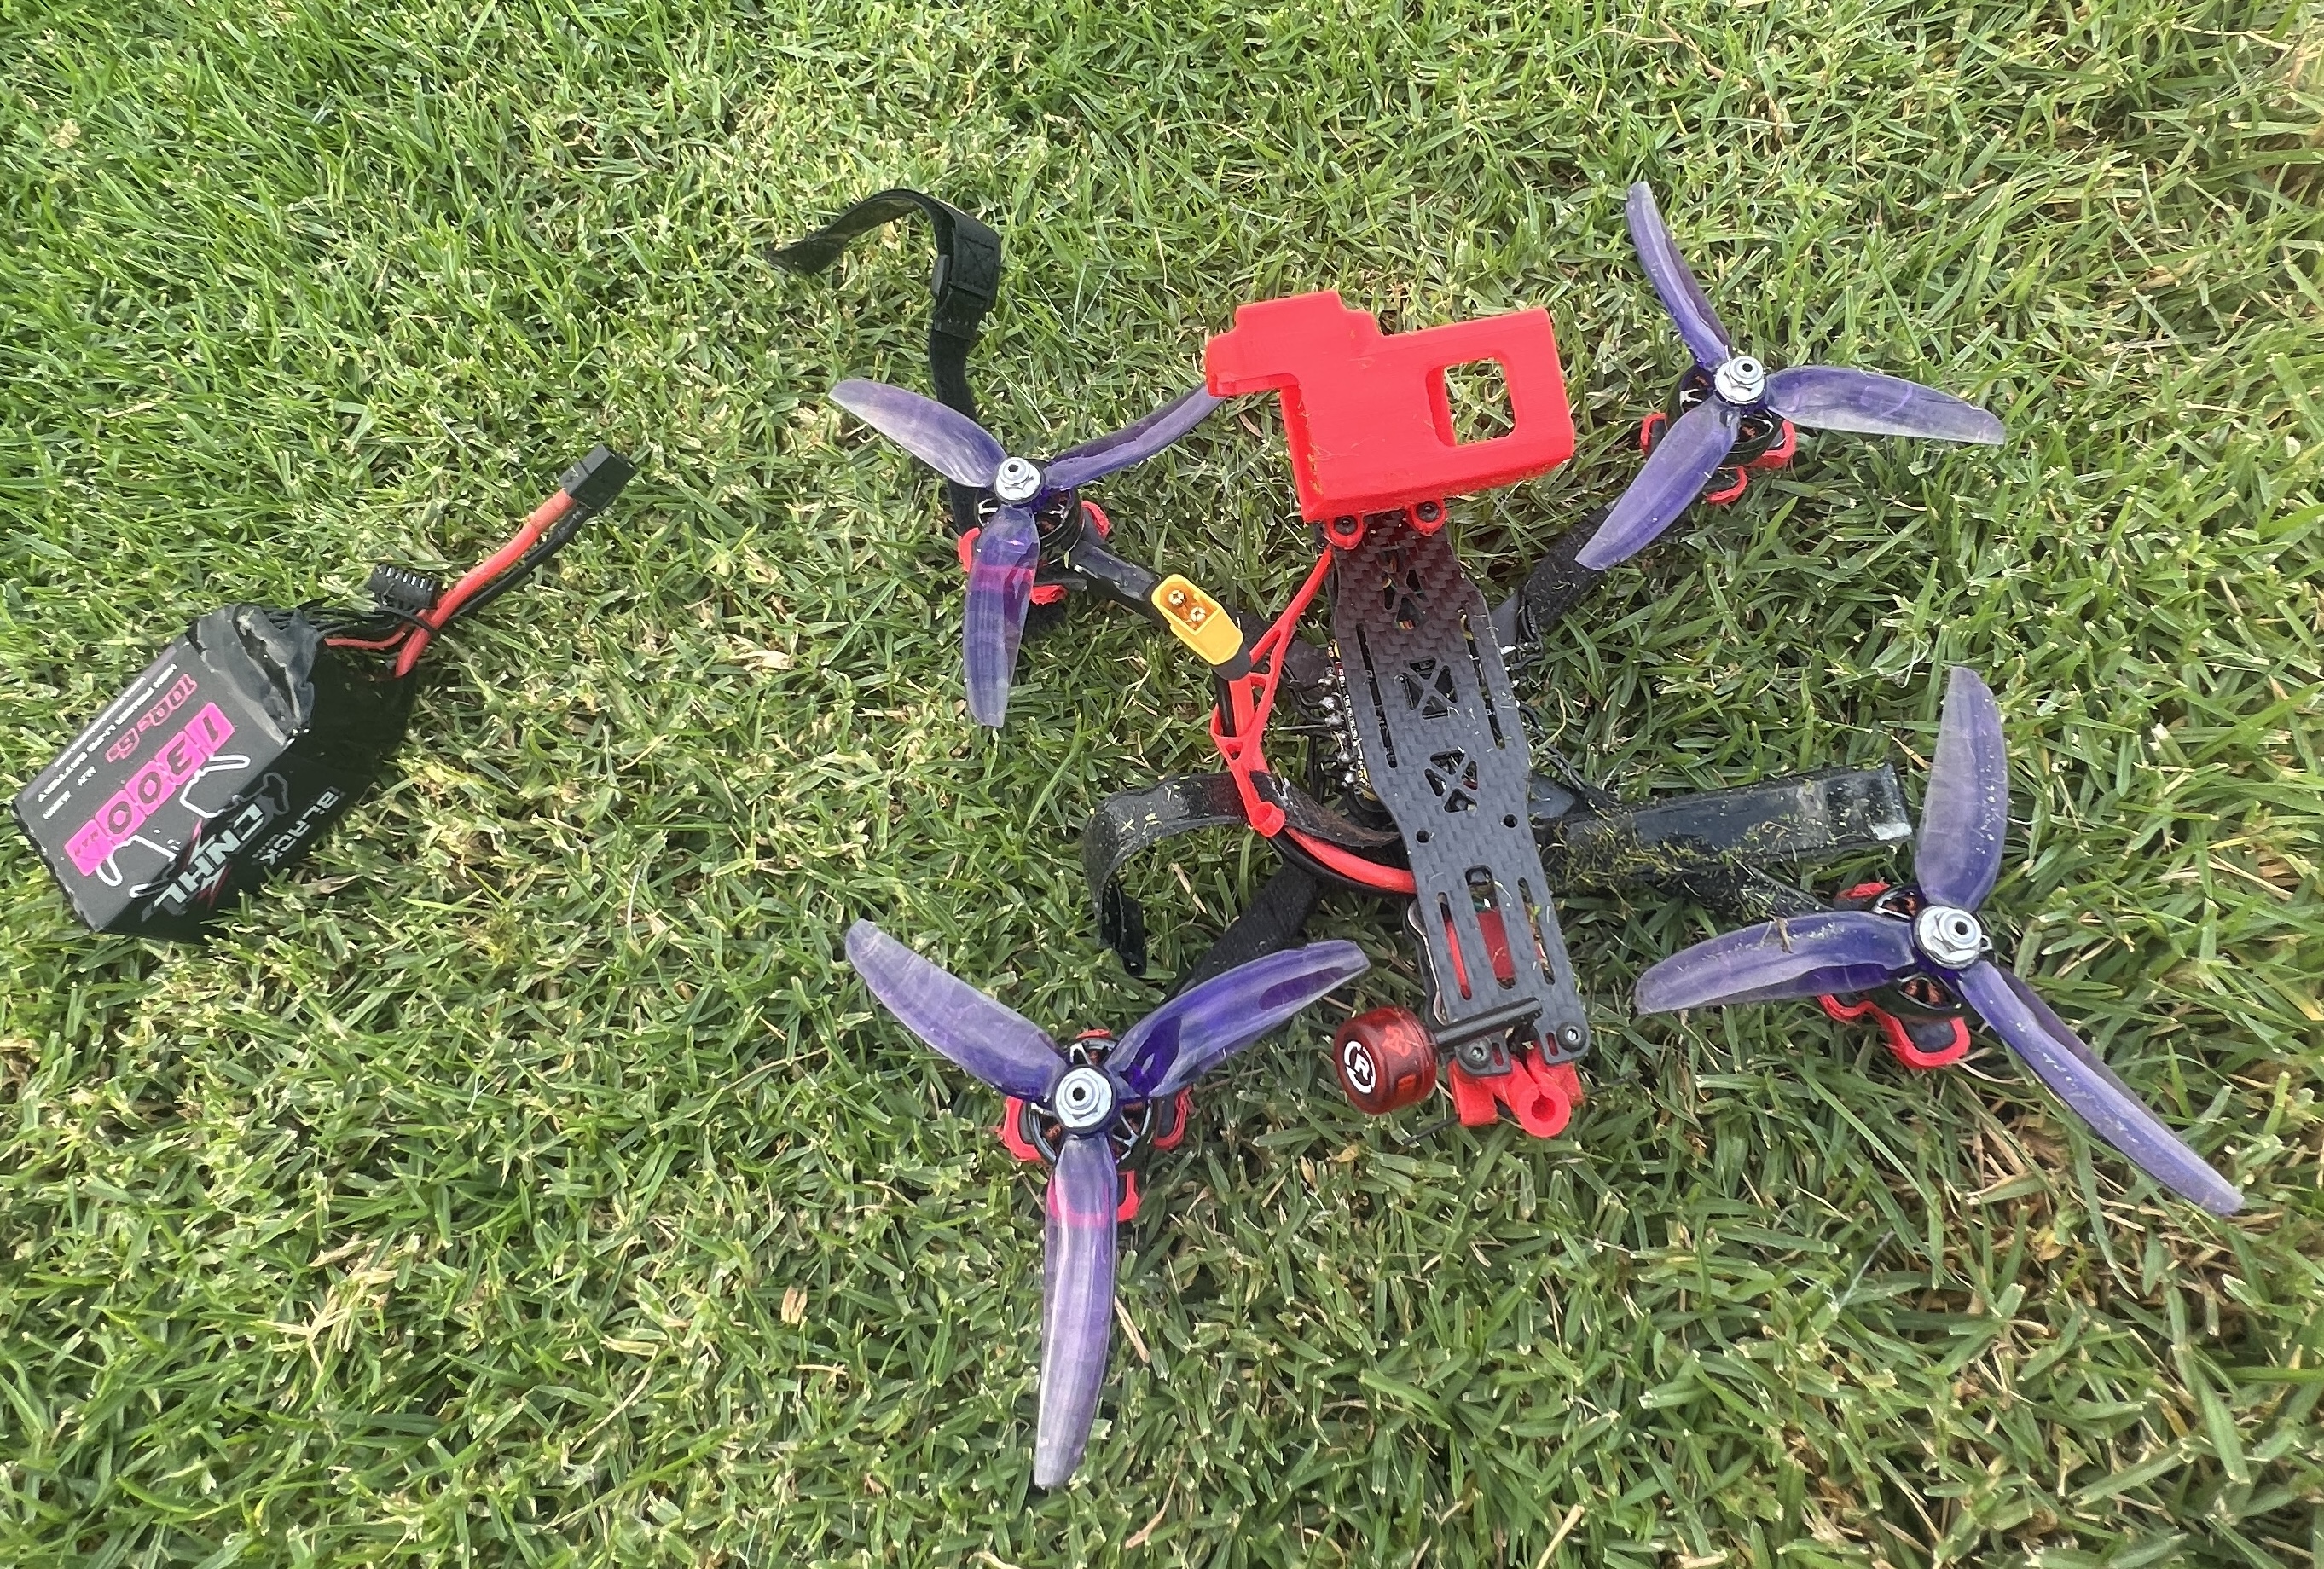
Quadcopter FPV DroneA simple wiring, assembly, and installation for a quadcopter FPV drone.